Advanced Robotic Systems
SanRobot
SanSCARA
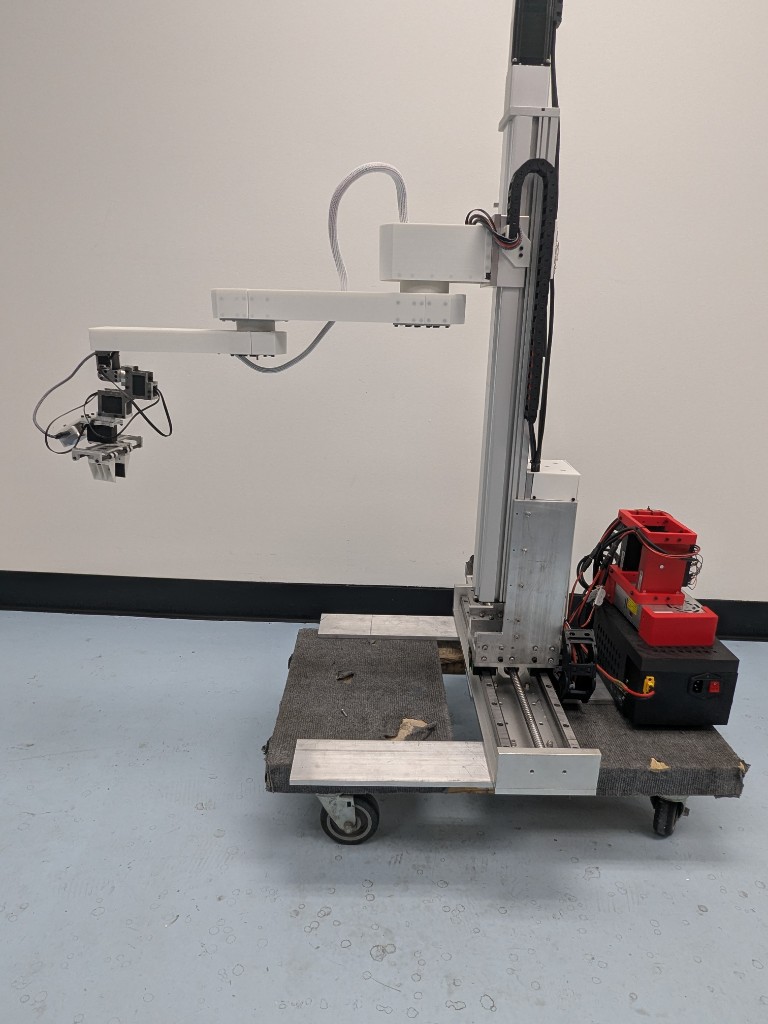
SanSCARA is a unique hybrid, industrial-quality 7-axis SCARA robot. Its aluminum components are CNC machined for rigidity and precision. It delivers 0.05 mm repeatability and extends the traditional SCARA architecture with a roll-yaw-pitch wrist at the end, enabling flexible tool orientation across a broad working envelope.
SR2i
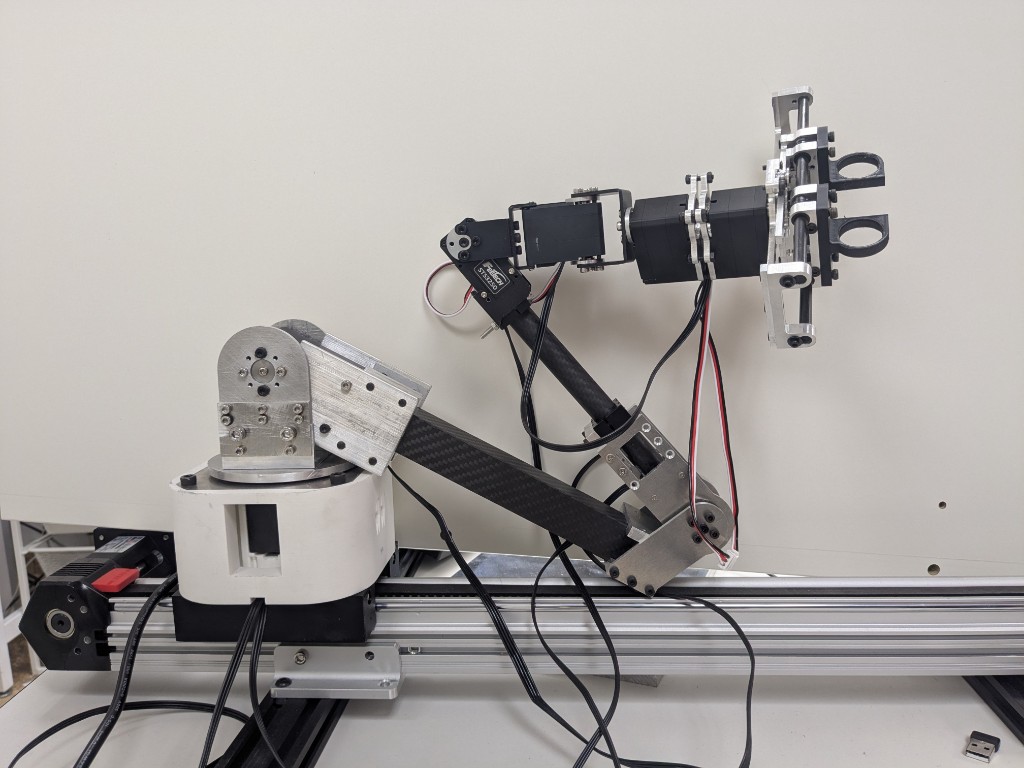
SR2i is a lightweight, industrial 7-axis robotic arm constructed from carbon fiber and aluminum. Precision ball bearings support smooth, rigid joint motion, while its high-performance mechanical design achieves 0.1 mm repeatability for accurate and versatile manipulation.
sGripper Ultra-Lightweight
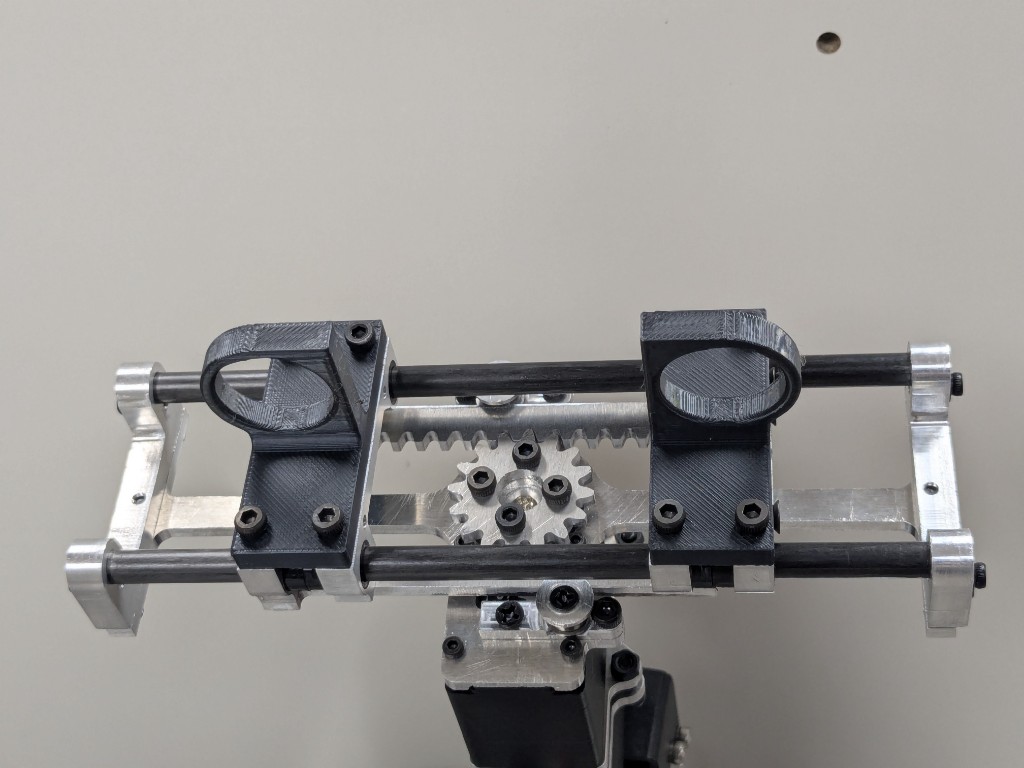
An ultra-lightweight rack-and-pinion gripper that uses carbon-fiber guides and a lightweight carriage. A miniature ball bearing keeps each rack firmly engaged with the pinion, preventing it from twisting or lifting away during operation. At just 150 grams including the motor, it is significantly lighter than other grippers of comparable quality while retaining a precise, rigid mechanism.
sROBOT v.1
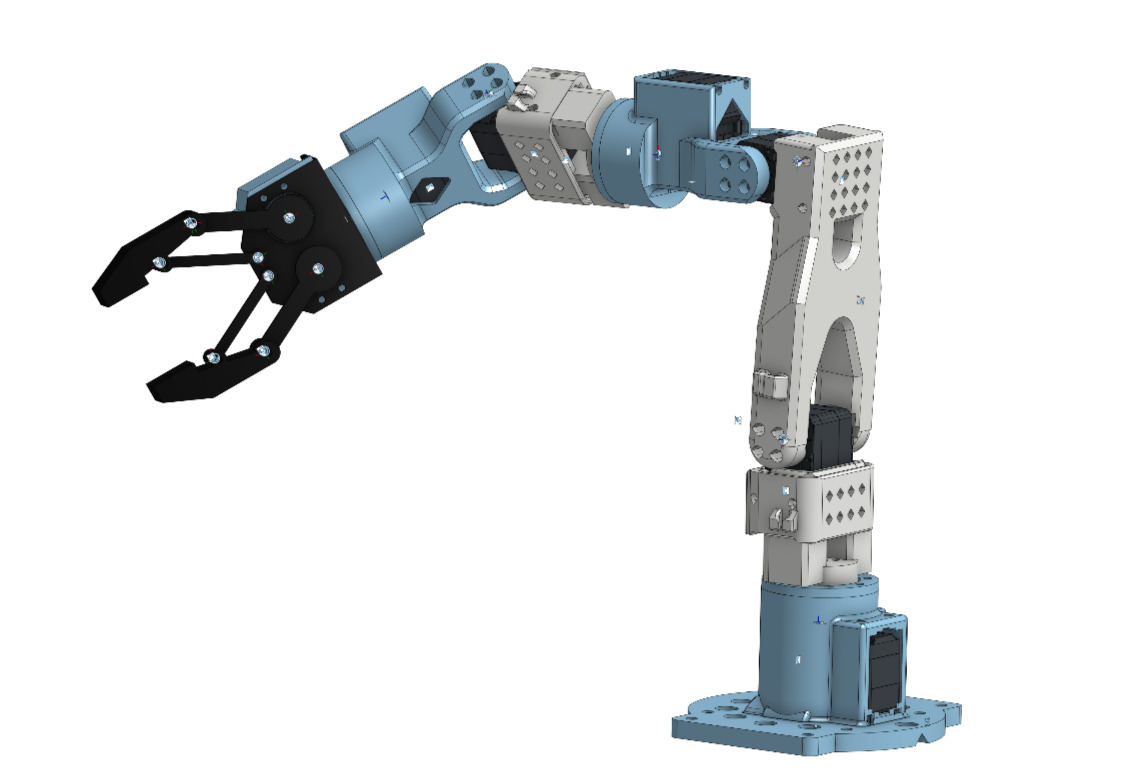
The srobotv1 is an advanced 7-axis robotic manipulator engineered for maximum stability and dexterity. By integrating bearings throughout the entire assembly, I eliminated the 1-degree base deflection that typically results in massive precision errors at the gripper.
Fire Detection Rover
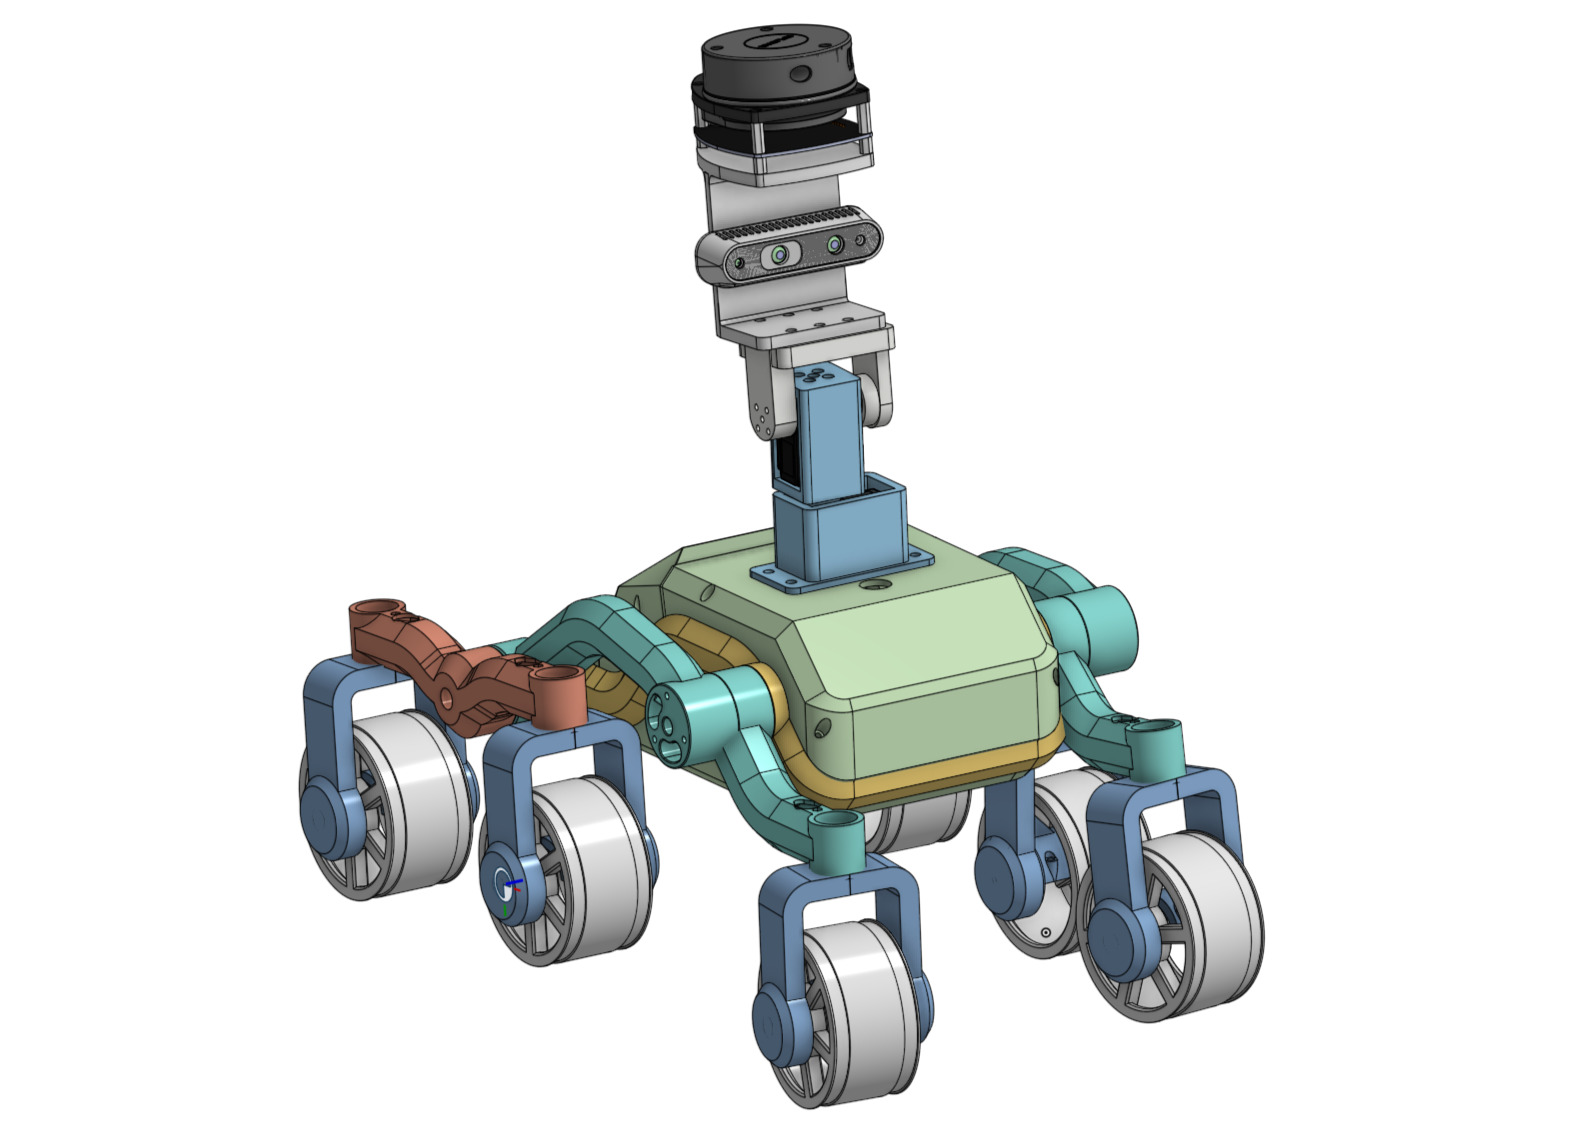
An autonomous safety solution designed for rapid response in high-risk environments. This project integrates multi-sensor data fusion to identify heat signatures and smoke patterns in real-time, providing a mobile shield against industrial hazards.
sHUMANOID v.1
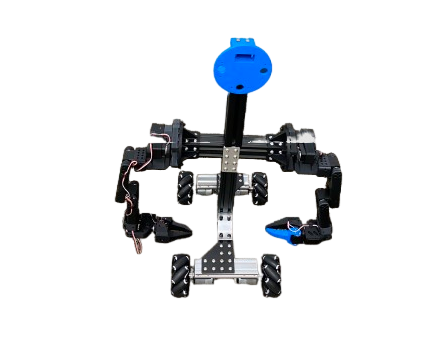
A mobile humanoid platform engineered for complex manipulation. Built with a robust extruded aluminum frame, the robot features a mecanum wheel base for omnidirectional movement, blending industrial strength with fluid agility.
sGRIPPER v.1
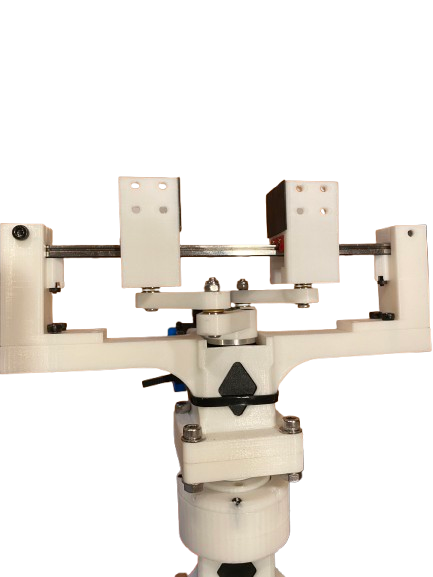
A high-precision end-effector featuring an industrial MGN 7 linear rail and a custom cam-based actuation mechanism. This architecture provides perfect parallel finger movement and high mechanical advantage.
About Sanatan Sinha
Sanatan Sinha is a middle schooler from San Jose who has completed various robotics projects.